
EV3 basics course. Ultrasonic Sensor. Move after object is removed (part2)
The robot detects an object. After the object is remove we want to make the LEGO robot move forward.
- #143
- 13 Oct 2015
The robot detects an object. After the object is remove we want to make the LEGO robot move forward.

Бележки за построяването на Петминутен робот.

This is a teacher's note about the math behind calculating gear ratios with for our lifting attachment. It math model we build in previous tutorials is not exactly correct and here is the explanation why.

This video tutorial contains a detailed explanation on how we accomplish the FIRST LEGO League 2018-2019 Into Orbit mission called M05. EXTRACTION. On every robotics competition we have the challenge to collect, carry and return to base a number of objects. It is just in different way every time.
What happens if we need to perform some actions simultaneously from the middle of a program. Let us assume that we have a multi-threaded task at hand, but before it we need to rotate our robot at 360 degrees.

Целта на това занптие е учениците да се забавляват с нов робот.

Нарочно откачете един от кабелите и наблюдавайте, какво ще направи робота.
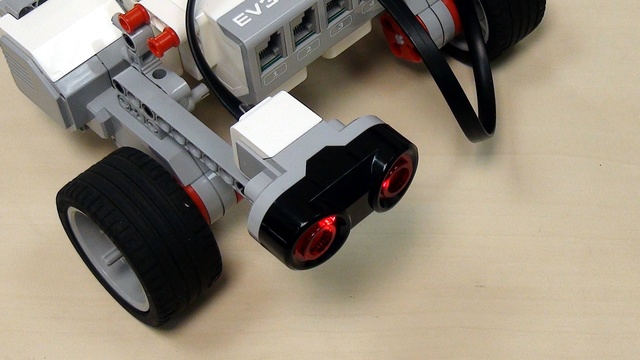
We are introducing the LEGO Mindstorms EV3 Ultrasonic Sensor. The first program is actually to detect an object and stop near it, at about 4 inches/10 centimeters. The ultrasonic sensor could be used during robotics competitions, but most of its use is for experiments.